PRBonn/depth_clustering là một trong những repo mã nguồn mở mà TopGit theo dõi, hiện có 1.3k sao, viết chủ yếu bằng C++. :taxi: Fast and robust clustering of point clouds generated with a Velodyne sensor.
Tóm tắt dựng từ metadata GitHub của chính dự án — chưa có bài review TopGit. Trang sẽ tự động cập nhật khi bài review đầy đủ được xuất bản.
VÌ SAO CHƯA CÓ REVIEW
TopGit viết bài đầy đủ cho repo có nhiều sao nhất và được yêu cầu nhiều nhất. Trang này là snapshot trong thời gian chờ — xem README gốc ở tab READ ME.
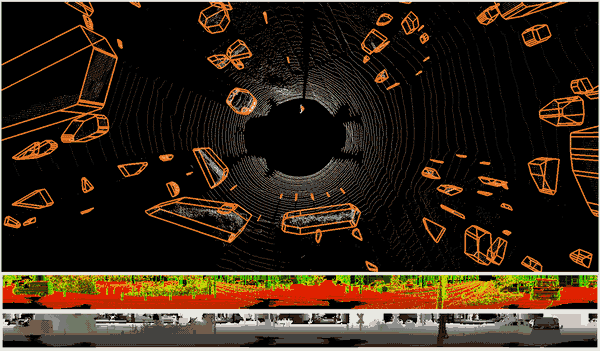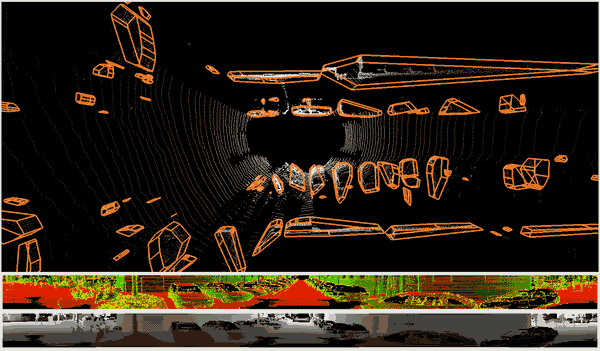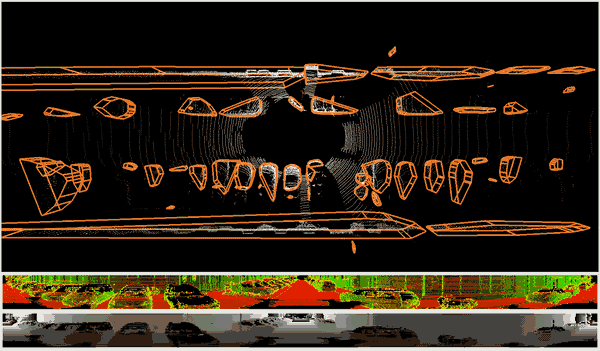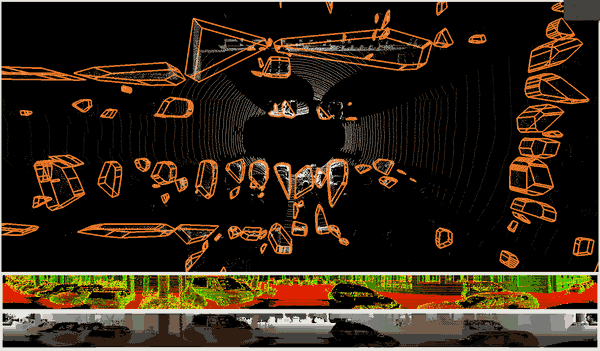
This is a fast and robust algorithm to segment point clouds taken with
Velodyne sensor into objects. It works with all available Velodyne sensors,
i.e. 16, 32 and 64 beam ones.
Check out a video that shows all objects outlined in orange:
Prerequisites
I recommend using a virtual environment in your catkin workspace (<catkin_ws>
in this readme) and will assume that you have it set up throughout this readme.
Please update your commands accordingly if needed. I will be using pipenv
that you can install with pip.
Set up workspace and catkin
Regardless of your system you will need to do the following steps:
cd <catkin_ws>            # navigate to the workspace
pipenv shell --fancy      # start a virtual environment
pip install catkin-tools  # install catkin-tools for building
mkdir src                 # create src dir if you don't have it already
# Now you just need to clone the repo:
git clone https://github.com/PRBonn/depth_clustering src/depth_clustering
System requirements
You will need OpenCV, QGLViewer, FreeGLUT, QT4 or QT5 and optionally PCL and/or
ROS. The following sections contain an installation command for various Ubuntu
systems (click folds to expand):
You might also need the latest GoogleTest binary installed on your systems. As Ubuntu is not shipped with these binaries by default, you would have to install them yourself or adapt the build script to build them from source.
Optional requirements
If you want to use PCL clouds and/or use ROS for data acquisition you can install the following:
(optional) PCL - needed for saving clouds to disk
(optional) ROS - needed for subscribing to topics
How to build?
This is a catkin package. So we assume that the code is in a catkin workspace
and CMake knows about the existence of Catkin. It should be already taken care
of if you followed the instructions here. Then
you can build it from the project folder:
mkdir build
cd build
cmake ..
make -j4
ctest -VV  # run unit tests, optional
It can also be built with catkin_tools if the code is inside catkin
workspace:
catkin build depth_clustering
P.S. in case you don't use catkin build you should reconsider your decision.
How to run?
See examples. There are ROS nodes as well as standalone
binaries. Examples include showing axis oriented bounding boxes around found
objects (these start with show_objects_ prefix) as well as a node to save all
segments to disk. The examples should be easy to tweak for your needs.
Run on real world data
Go to folder with binaries:
cd <path_to_project>/build/devel/lib/depth_clustering
Alternatively, you can run the data from Qt GUI (as in video):
./qt_gui_app
Once the GUI is shown, click on OpenFolder button and choose the
folder where you have unpacked the png files, e.g. data/scenario1/.
Navigate the viewer with arrows and controls seen on screen.
Other data
There are also examples on how to run the processing on KITTI data and on ROS
input. Follow the --help output of each of the examples for more details.
Also you can load the data from the GUI. Make sure you are loading files with
correct extension (*.txt and *.bin for KITTI, *.png for Moosmann's data).
Documentation
You should be able to get Doxygen documentation by running:
cd doc/
doxygen Doxyfile.conf
Related publications
Please cite related papers if you use this code:
@InProceedings{bogoslavskyi16iros,
title     = {Fast Range Image-Based Segmentation of Sparse 3D Laser Scans for Online Operation},
author    = {I. Bogoslavskyi and C. Stachniss},
booktitle = {Proc. of The International Conference on Intelligent Robots and Systems (IROS)},
year      = {2016},
url       = {http://www.ipb.uni-bonn.de/pdfs/bogoslavskyi16iros.pdf}
}
@Article{bogoslavskyi17pfg,
title   = {Efficient Online Segmentation for Sparse 3D Laser Scans},
author  = {I. Bogoslavskyi and C. Stachniss},
journal = {PFG -- Journal of Photogrammetry, Remote Sensing and Geoinformation Science},
year    = {2017},
pages   = {1--12},
url     = {https://link.springer.com/article/10.1007%2Fs41064-016-0003-y},
}
Trang TopGit này là một snapshot — tab "Readme" hiển thị nguyên văn README của repo (đã bỏ link, giữ ảnh). Repo GitHub ở github.com/PRBonn/depth_clustering là nguồn chính thức.
PRBonn/depth_clustering có phải mã nguồn mở không?
Có — PRBonn/depth_clustering phát hành theo license MIT, nghĩa là mã nguồn mở để đọc, fork và (tùy license) tái sử dụng. Mã: github.com/PRBonn/depth_clustering.
PRBonn/depth_clustering có website riêng không?
TopGit chưa ghi nhận URL trang chủ cho PRBonn/depth_clustering. Phần README ở tab phía trên thường có link demo, hoặc xem mô tả GitHub của repo.
PRBonn/depth_clustering dùng license gì?
PRBonn/depth_clustering phát hành theo license MIT. Nên mở file LICENSE trên GitHub để xác nhận — license metadata đôi khi lệch với thực tế dự án.
PRBonn/depth_clustering là gì?
PRBonn/depth_clustering (PRBonn/depth_clustering) là dự án C++ trên GitHub. Theo mô tả gốc: :taxi: Fast and robust clustering of point clouds generated with a Velodyne sensor.
Đọc đầy đủ README ở tab phía trên.
Vẫn đang phân vân về depth_clustering?
Một cú bấm sẽ gửi câu hỏi kèm trang này cho AI — xem AI nói gì về depth_clustering.

 /depth_clustering