UZ-SLAMLab/ORB_SLAM3 is one of the open-source repositories TopGit tracks, currently at 9.2k stars, written primarily in C++. ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual-Inertial and Multi-Map SLAM
Snapshot summary built from the project's own GitHub metadata — there's no written TopGit review yet. The page will update automatically when a full review is published.
WHY NO REVIEW YET
TopGit writes full reviews for the most-starred, most-requested repositories. This page is a snapshot until then — see the READ ME tab for the original README in full.
Authors: Carlos Campos, Richard Elvira, Juan J. Gómez Rodríguez, José M. M. Montiel, Juan D. Tardos.
The Changelog describes the features of each version.
ORB-SLAM3 is the first real-time SLAM library able to perform Visual, Visual-Inertial and Multi-Map SLAM with monocular, stereo and RGB-D cameras, using pin-hole and fisheye lens models. In all sensor configurations, ORB-SLAM3 is as robust as the best systems available in the literature, and significantly more accurate.
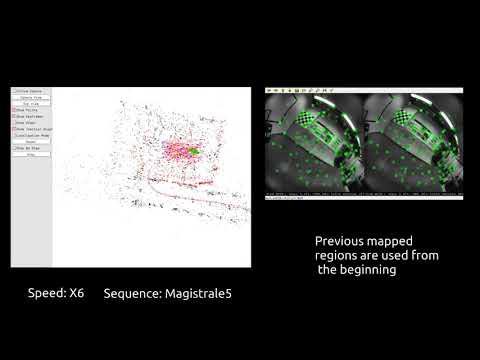
We provide examples to run ORB-SLAM3 in the EuRoC dataset using stereo or monocular, with or without IMU, and in the TUM-VI dataset using fisheye stereo or monocular, with or without IMU. Videos of some example executions can be found at ORB-SLAM3 channel.
This software is based on ORB-SLAM2 developed by Raul Mur-Artal, Juan D. Tardos, J. M. M. Montiel and Dorian Galvez-Lopez (DBoW2).
Related Publications:
[ORB-SLAM3] Carlos Campos, Richard Elvira, Juan J. Gómez Rodríguez, José M. M. Montiel and Juan D. Tardós, ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual-Inertial and Multi-Map SLAM, IEEE Transactions on Robotics 37(6):1874-1890, Dec. 2021. PDF.
[IMU-Initialization] Carlos Campos, J. M. M. Montiel and Juan D. Tardós, Inertial-Only Optimization for Visual-Inertial Initialization, ICRA 2020. PDF
[ORBSLAM-Atlas] Richard Elvira, J. M. M. Montiel and Juan D. Tardós, ORBSLAM-Atlas: a robust and accurate multi-map system, IROS 2019. PDF.
[ORBSLAM-VI] Raúl Mur-Artal, and Juan D. Tardós, Visual-inertial monocular SLAM with map reuse, IEEE Robotics and Automation Letters, vol. 2 no. 2, pp. 796-803, 2017. PDF.
[Stereo and RGB-D] Raúl Mur-Artal and Juan D. Tardós. ORB-SLAM2: an Open-Source SLAM System for Monocular, Stereo and RGB-D Cameras. IEEE Transactions on Robotics, vol. 33, no. 5, pp. 1255-1262, 2017. PDF.
[Monocular] Raúl Mur-Artal, José M. M. Montiel and Juan D. Tardós. ORB-SLAM: A Versatile and Accurate Monocular SLAM System. IEEE Transactions on Robotics, vol. 31, no. 5, pp. 1147-1163, 2015. (2015 IEEE Transactions on Robotics Best Paper Award). PDF.
[DBoW2 Place Recognition] Dorian Gálvez-López and Juan D. Tardós. Bags of Binary Words for Fast Place Recognition in Image Sequences. IEEE Transactions on Robotics, vol. 28, no. 5, pp. 1188-1197, 2012. PDF
1. License
ORB-SLAM3 is released under GPLv3 license. For a list of all code/library dependencies (and associated licenses), please see Dependencies.md.
For a closed-source version of ORB-SLAM3 for commercial purposes, please contact the authors: orbslam (at) unizar (dot) es.
If you use ORB-SLAM3 in an academic work, please cite:
@article{ORBSLAM3_TRO,
  title={{ORB-SLAM3}: An Accurate Open-Source Library for Visual, Visual-Inertial
           and Multi-Map {SLAM}},
  author={Campos, Carlos AND Elvira, Richard AND G\´omez, Juan J. AND Montiel,
          Jos\'e M. M. AND Tard\'os, Juan D.},
  journal={IEEE Transactions on Robotics},
  volume={37},
  number={6},
  pages={1874-1890},
  year={2021}
 }
2. Prerequisites
We have tested the library in Ubuntu 16.04 and 18.04, but it should be easy to compile in other platforms. A powerful computer (e.g. i7) will ensure real-time performance and provide more stable and accurate results.
C++11 or C++0x Compiler
We use the new thread and chrono functionalities of C++11.
Pangolin
We use Pangolin for visualization and user interface. Dowload and install instructions can be found at: https://github.com/stevenlovegrove/Pangolin.
OpenCV
We use OpenCV to manipulate images and features. Dowload and install instructions can be found at: http://opencv.org. Required at leat 3.0. Tested with OpenCV 3.2.0 and 4.4.0.
Eigen3
Required by g2o (see below). Download and install instructions can be found at: http://eigen.tuxfamily.org. Required at least 3.1.0.
DBoW2 and g2o (Included in Thirdparty folder)
We use modified versions of the DBoW2 library to perform place recognition and g2o library to perform non-linear optimizations. Both modified libraries (which are BSD) are included in the Thirdparty folder.
Python
Required to calculate the alignment of the trajectory with the ground truth. Required Numpy module.
(win) http://www.python.org/downloads/windows
(deb) sudo apt install libpython2.7-dev
(mac) preinstalled with osx
ROS (optional)
We provide some examples to process input of a monocular, monocular-inertial, stereo, stereo-inertial or RGB-D camera using ROS. Building these examples is optional. These have been tested with ROS Melodic under Ubuntu 18.04.
We provide a script build.sh to build the Thirdparty libraries and ORB-SLAM3. Please make sure you have installed all required dependencies (see section 2). Execute:
cd ORB_SLAM3
chmod +x build.sh
./build.sh
This will create libORB_SLAM3.so at lib folder and the executables in Examples folder.
4. Running ORB-SLAM3 with your camera
Directory Examples contains several demo programs and calibration files to run ORB-SLAM3 in all sensor configurations with Intel Realsense cameras T265 and D435i. The steps needed to use your own camera are:
Calibrate your camera following Calibration_Tutorial.pdf and write your calibration file your_camera.yaml
Modify one of the provided demos to suit your specific camera model, and build it
Connect the camera to your computer using USB3 or the appropriate interface
Run ORB-SLAM3. For example, for our D435i camera, we would execute:
EuRoC dataset was recorded with two pinhole cameras and an inertial sensor. We provide an example script to launch EuRoC sequences in all the sensor configurations.
Download a sequence (ASL format) from http://projects.asl.ethz.ch/datasets/doku.php?id=kmavvisualinertialdatasets
Open the script "euroc_examples.sh" in the root of the project. Change pathDatasetEuroc variable to point to the directory where the dataset has been uncompressed.
Execute the following script to process all the sequences with all sensor configurations:
./euroc_examples
Evaluation
EuRoC provides ground truth for each sequence in the IMU body reference. As pure visual executions report trajectories centered in the left camera, we provide in the "evaluation" folder the transformation of the ground truth to the left camera reference. Visual-inertial trajectories use the ground truth from the dataset.
Execute the following script to process sequences and compute the RMS ATE:
./euroc_eval_examples
6. TUM-VI Examples
TUM-VI dataset was recorded with two fisheye cameras and an inertial sensor.
Download a sequence from https://vision.in.tum.de/data/datasets/visual-inertial-dataset and uncompress it.
Open the script "tum_vi_examples.sh" in the root of the project. Change pathDatasetTUM_VI variable to point to the directory where the dataset has been uncompressed.
Execute the following script to process all the sequences with all sensor configurations:
./tum_vi_examples
Evaluation
In TUM-VI ground truth is only available in the room where all sequences start and end. As a result the error measures the drift at the end of the sequence.
Execute the following script to process sequences and compute the RMS ATE:
./tum_vi_eval_examples
7. ROS Examples
Building the nodes for mono, mono-inertial, stereo, stereo-inertial and RGB-D
Tested with ROS Melodic and ubuntu 18.04.
Add the path including Examples/ROS/ORB_SLAM3 to the ROS_PACKAGE_PATH environment variable. Open .bashrc file:
gedit ~/.bashrc
and add at the end the following line. Replace PATH by the folder where you cloned ORB_SLAM3:
For a monocular input from topic /camera/image_raw run node ORB_SLAM3/Mono. You will need to provide the vocabulary file and a settings file. See the monocular examples above.
For a monocular input from topic /camera/image_raw and an inertial input from topic /imu, run node ORB_SLAM3/Mono_Inertial. Setting the optional third argument to true will apply CLAHE equalization to images (Mainly for TUM-VI dataset).
For a stereo input from topic /camera/left/image_raw and /camera/right/image_raw run node ORB_SLAM3/Stereo. You will need to provide the vocabulary file and a settings file. For Pinhole camera model, if you provide rectification matrices (see Examples/Stereo/EuRoC.yaml example), the node will recitify the images online, otherwise images must be pre-rectified. For FishEye camera model, rectification is not required since system works with original images:
For a stereo input from topics /camera/left/image_raw and /camera/right/image_raw, and an inertial input from topic /imu, run node ORB_SLAM3/Stereo_Inertial. You will need to provide the vocabulary file and a settings file, including rectification matrices if required in a similar way to Stereo case:
For an RGB-D input from topics /camera/rgb/image_raw and /camera/depth_registered/image_raw, run node ORB_SLAM3/RGBD. You will need to provide the vocabulary file and a settings file. See the RGB-D example above.
Running ROS example: Download a rosbag (e.g. V1_02_medium.bag) from the EuRoC dataset (http://projects.asl.ethz.ch/datasets/doku.php?id=kmavvisualinertialdatasets). Open 3 tabs on the terminal and run the following command at each tab for a Stereo-Inertial configuration:
rosbag play --pause V1_02_medium.bag /cam0/image_raw:=/camera/left/image_raw /cam1/image_raw:=/camera/right/image_raw /imu0:=/imu
Once ORB-SLAM3 has loaded the vocabulary, press space in the rosbag tab.
Remark: For rosbags from TUM-VI dataset, some play issue may appear due to chunk size. One possible solution is to rebag them with the default chunk size, for example:
A flag in include\Config.h activates time measurements. It is necessary to uncomment the line #define REGISTER_TIMES to obtain the time stats of one execution which is shown at the terminal and stored in a text file(ExecTimeMean.txt).
9. Calibration
You can find a tutorial for visual-inertial calibration and a detailed description of the contents of valid configuration files at Calibration_Tutorial.pdf
How active is development on UZ-SLAMLab/ORB_SLAM3?
The most recent commit recorded on UZ-SLAMLab/ORB_SLAM3 was 2.3 years ago, based on the GitHub push timestamp. The repository has 3.2k forks — one of the better signals of community interest.
How many stars does UZ-SLAMLab/ORB_SLAM3 have?
UZ-SLAMLab/ORB_SLAM3 has 9.2k GitHub stars — refresh the page for the live number, or check github.com/UZ-SLAMLab/ORB_SLAM3. TopGit mirrors GitHub's count but does not claim minute-by-minute accuracy.
Is UZ-SLAMLab/ORB_SLAM3 open source?
Yes — UZ-SLAMLab/ORB_SLAM3 ships under the GPL-3.0 license, which makes its source code freely readable (and, depending on license terms, forkable and reusable). Source: github.com/UZ-SLAMLab/ORB_SLAM3.
What is UZ-SLAMLab/ORB_SLAM3?
UZ-SLAMLab/ORB_SLAM3 (UZ-SLAMLab/ORB_SLAM3) is a C++ project on GitHub. From the project's own README: ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual-Inertial and Multi-Map SLAM
What language is UZ-SLAMLab/ORB_SLAM3 written in?
UZ-SLAMLab/ORB_SLAM3 is written primarily in C++. GitHub's language field is based on the largest share of bytes in the default branch.
What license does UZ-SLAMLab/ORB_SLAM3 use?
UZ-SLAMLab/ORB_SLAM3 is released under the GPL-3.0 license. Always verify the LICENSE file directly on GitHub for the authoritative terms — license strings can be edited out of sync with a project's actual stance.
Where do I read more about UZ-SLAMLab/ORB_SLAM3?
This TopGit page is a snapshot — the READ ME tab shows the project's own README content (links stripped, images preserved). The GitHub repository at github.com/UZ-SLAMLab/ORB_SLAM3 is the definitive source.
Read full README in the tab above.
Want a second opinion on ORB_SLAM3?
Ask an AI that can read this page — one click and you get its take on ORB_SLAM3.

 /ORB_SLAM3